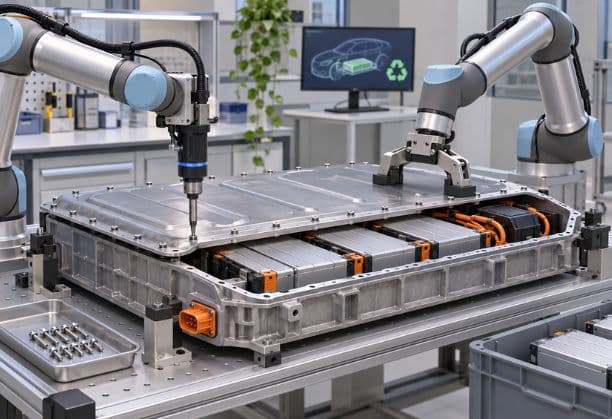
Robotic Cooperative Disassembly of End-of-Life EV Batteries: Force-Controlled Automated Unscrewing with Two Collaborating Robots
Principal Investigator
Prof. Anuj Kumar Tiwari
Objective
- Develop and demonstrate two cooperating robots for reliable, force-controlled unscrewing of an EV battery-module mockup.
Description
- The aim of the project is to take the unscrewing step of EV battery pack disassembly out of human hands, using two cooperating cobots.
Impact
- 0